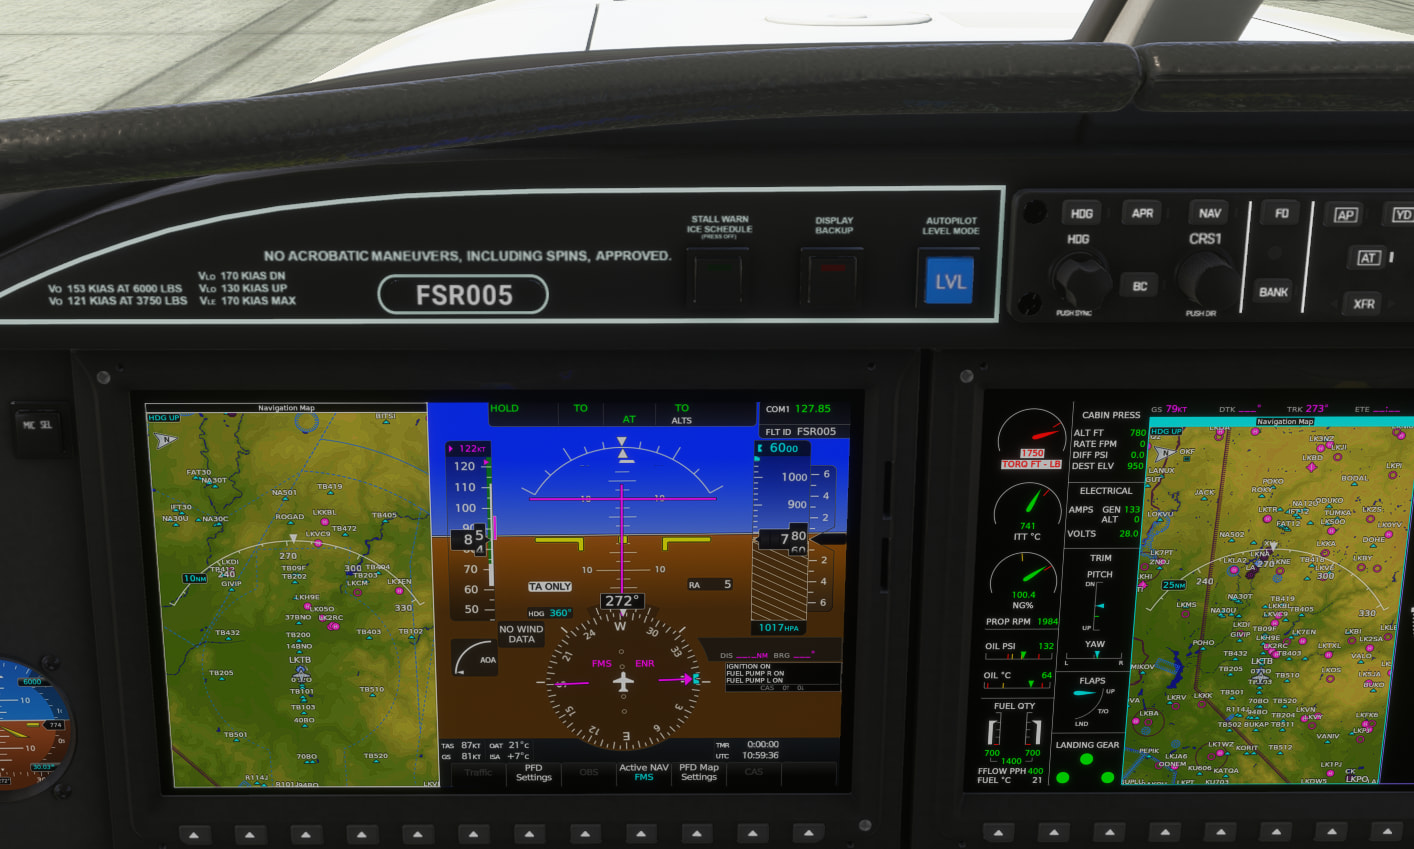
When Autothrottle is armed before takeoff, advancing power lever full forward will cause Autothrottle HOLD mode to activate, which will cause engine overtorque.
REPRODUCTION STEPS
Please list clear steps you took in order to help our test team reproduce the same issue:
Click on AT button on autopilot panel before takeoff
Advance power lever full forward
AT HOLD mode will activate, but engine will have 1750 torque (overtorque)
Hmm, is that how it is supposed to be operated? HOLD mode usually indicates the autothrottle servo is inhibited from moving the power lever. Does the autothrottle move the power lever full forward or did you? If an overtorque develops while HOLD mode is active, the autothrottle will not solve it.
I’m not able to find any POH of a M600 with autothrottle, no idea how it is supposed to work. I did find some technical drawings of the throttle quadrant which seems to be fully mechanical.
If correct that would mean that the autothrottle is servo operated and the power lever should not be moved to MAX position for take-off (like with other PT6 powered aircraft).
Also interesting that it has a HOLD mode as torque naturally increases during take-off due to ramrise, in HOLD mode the autothrottle would not be able to limit the torque and prevent overtorque…
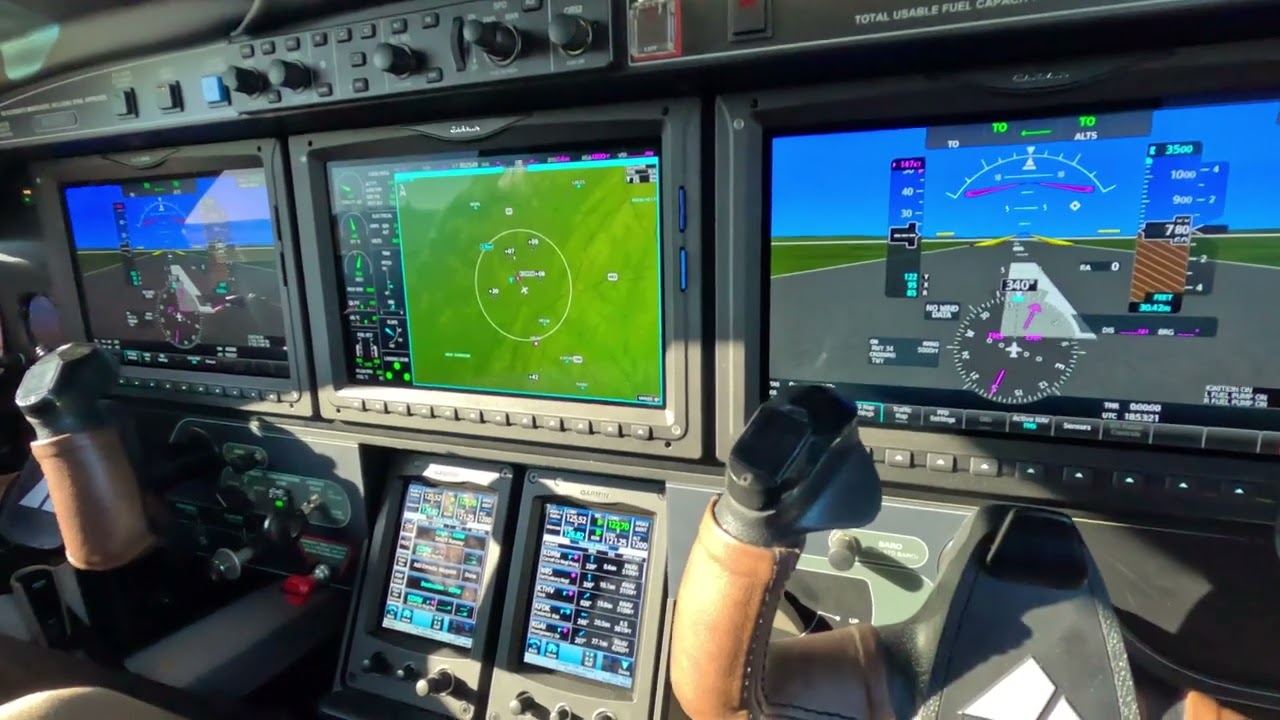
I found this video, can’t see what they do with the throttle, I’m assuming you move the power lever forward until the autothrottle servo engages (not full forward). It does not seem to have a HOLD mode:
Edit:
Apparently the M600 does have a HOLD mode according to the M600 G3000 pilot guide:
Although I have searched half Youtube for M600 and M700s taking off and so far not found a single example going from TO → HOLD.
It is a bit usual to have a HOLD mode on something like a PT-6 which does not have a separate torque / temperature limiter or FADEC.
Having to manually adjust the power to prevent redline torque during take-off roll makes the autothrottle TO mode lose it’s purpose.
I don’t own the product. But I went through half Youtube and didn’t see any M600 or M700 go into HOLD mode during take-off. So I assume it does not exist, it wouldn’t make sense on a PT-6.
I own and fly my M600SLS. I use my sim mostly for IFR training and flying to airports where I’m going IRL. I’m not a technically expert simmer by any means, I just bought the M600 yesterday,
Specifically, on takeoff you arm the autothrottle AT button, manually move the throttle forward to about 400 NG, and the AT engages to max continuous power MCP. That’s it. There’s no HOLD function, never heard of it. In the sim the AT doesn’t work on takeoff with my Honeycomb, but it could be just me. The AT does seem to work ok in flight, more so in the Manual mode than FMS mode. But the Sim flies 20kts faster than IRL
I think all that matters is having adequate takeoff speed and power, which you achieve by setting the power lever to >700ft-lbs. It then takes over at that point to handle the climb out after takeoff. Seems to be working as designed as far as I can tell based on the available checklist, at least.
It should show TO as soon as the autothrottle engages and from what I have seen online, it should keep displaying TO throughout the take-off, no HOLD or anything else.
So the checklist within the G3000 is incorrect? I’m curious what their source is for that and what the official M600 POH and checklist would advise in its place.
I don’t know what the checklist says, I have seen many videos on Youtube of M600s and M700s taking off. It works like any other aircraft, power levers forward until the AT engages (AT green on FMA), the AT then sets redline torque for take-off.
Then in my opinion the “bug” here is with the checklist not matching IRL procedures, but if you follow the aircraft’s checklist for takeoff with AT then the engine is never overtorqued (as this bug alleges).
Kind of related is the HOLD mode that apparently acrivates during take-off which is also written in the M600 G3000 guide but I can’t find any proof of after watching many videos on YT of M600 / M700s taking off. During HOLD mode, the autothrottle servo will not move the power lever, and then it might overtorque and not correct for it.
Following the checklist in the M600’s G3000 I don’t see any mention of the HOLD mode at all, nor does it ever engage if I follow the checklist for takeoff power application as described above.